보드 장착형 카메라 광학 시스템

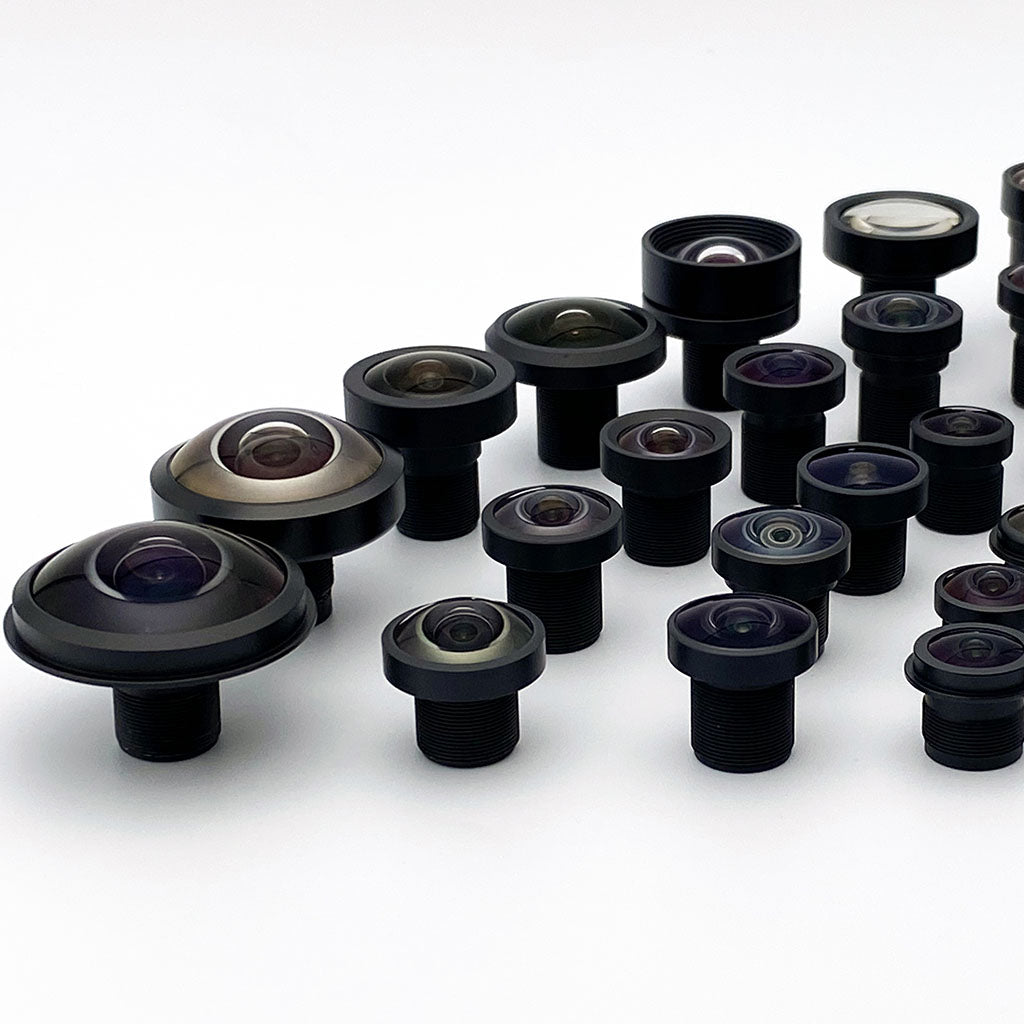
보드 레벨 카메라 모듈용 임베디드 비전 렌즈

Jetson, Raspberry Pi 및 기타 MIPI-CSI2 카메라 모듈의 PCB 장착형 홀더에 직접 나사로 고정되는 M12(S-마운트) 렌즈로, 센서 커버리지, 주광선 각도 일치도 및 홀더 높이를 기준으로 선정되었습니다.

The lenses below are the designs already used in board-camera integration work, chosen on image circle, chief ray angle match, and holder height rather than headline focal length. If you want the full catalog rather than the embedded subset, browse all M12 lenses.

0.8mm–7.8mm Featured focal lengths
F/1.45–F/2.3 Featured apertures
3g–15g M12 렌즈 무게
임베디드 비전 시스템, 싱글 보드 컴퓨터에 연결된 보드 레벨 M12 카메라

M12 (S-mount) lenses are the default for embedded vision because they thread directly into a PCB-mounted holder at 3g-15g, cover sensors up to 1/1.8 inch typically with select designs to 2/3 inch, and cost a fraction of industrial C-mount optics. Use C-mount or CS-mount only when the application needs an adjustable iris, a larger sensor, or a level of aberration correction the chosen M12 design does not reach.

이 페이지의 가이드에서는 센서 및 주광선 각도 매칭, Jetson 및 Raspberry Pi 카메라 모듈과의 보드 수준 통합, 그리고 대부분의 임베디드 렌즈 선정에 영향을 미치는 전력·크기·비용 간의 절충점에 대해 다룹니다.

임베디드 애플리케이션별 렌즈 선정

카메라가 수행해야 할 작업에 따라 초점 거리, 조리개 값, 그리고 렌즈에 방수 처리나 적외선 보정이 필요한지 여부가 결정됩니다.

엣지 AI 및 NVIDIA Jetson 플랫폼

Jetson Nano, Xavier NX 및 Orin 모듈은 일반적으로 M12 홀더를 사용하여 MIPI-CSI2 카메라 보드와 결합됩니다. 팔 길이에서 실내 규모에 이르는 범용 비전 용도의 경우, 4mm~8mm 초점 거리가 대부분의 사용 사례를 커버하며, 2mm~3mm는 세밀한 디테일보다 넓은 시야 확보가 더 중요한 서라운드 뷰 및 장애물 감지에 적합합니다.

로봇공학 및 AMR 내비게이션

Mobile robots typically run two different camera roles on two different lenses. Obstacle avoidance benefits from wide-angle or fisheye coverage. Calibrated bearings, stereo depth, and metric distance estimation still require accurate geometry. SLAM runs on either: calibrated fisheye and omnidirectional camera models are standard in current SLAM stacks, so what the front end needs is a camera model that fits the lens, a calibration that holds, well-localized features, and enough field of view. Low distortion keeps a plain pinhole model valid and skips the undistort step, which is why it stays the simpler starting point.

감시 및 보안

주야간 촬영을 위해서는 근적외선을 투과할 수 있는 방법과 두 대역 모두에서 초점을 유지할 수 있는 적외선 보정 렌즈가 모두 필요합니다. 고정형 적외선 차단 필터가 장착된 표준 렌즈는 근적외선을 차단하기 때문에, 밤에 850nm 조명기가 켜지면 카메라는 사실상 시야를 잃게 됩니다. 저조도 성능의 경우, 조리개 값이 다른 대부분의 사양보다 더 중요합니다. F/1.4 렌즈는 F/2.8 렌즈보다 약 4배 더 많은 빛을 받아들입니다.

드론 및 무인항공기(UAV)

Weight is payload budget on a drone. Motor vibration adds micro-blur, and a climb can carry the camera across a wider temperature range than a fixed ground install ever sees, though how wide and how fast depends on the mission profile, the weather, and how the enclosure is vented.

Construction is a shortlisting signal rather than a thermal spec: athermal focus is a design result, not a material label, and neither glass nor metal implies a vibration or ingress rating. Check the measured thermal focus behavior, the vibration spec, and the IP code on the SKU you plan to fly.

의료 영상 및 내시경

Ultra-compact M8 lenses fit the space constraints of endoscopes and medical imaging probes, typically at short working distances (5mm-30mm) and small image circles. Off-the-shelf parts like these belong in prototypes and non-diagnostic imaging; once a lens touches patients, faces sterilization cycles, or falls under regulatory review, it needs a custom qualification program, so bring those requirements to engineering before specifying a part.

임베디드 리더기에서의 바코드 판독 및 OCR

휴대용 및 터널 장착형 바코드 리더기는 사실상 임베디드 비전 시스템과 다름없습니다. 소형 센서, 짧은 작동 거리, 그리고 일반적으로 부피가 큰 렌즈를 장착할 공간이 거의 없다는 점이 특징입니다. 초점 거리가 짧은(8mm~16mm) 렌즈는 근거리에서 미세한 바코드 모듈과 작은 텍스트를 선명하게 포착하며, 왜곡이 적어 화각 가장자리의 판독률도 중심부와 비슷한 수준을 유지합니다.

임베디드 비전용 최고의 M12 렌즈

The six lenses named in the spec table further down span 0.8mm to 7.8mm focal length, at F/1.45 to F/2.3 in the variants listed, covering general-purpose vision, wide-angle low-light surveillance, low-distortion SLAM, and ultra-wide surround view on Jetson and Raspberry Pi camera modules. The cards below pull live from the collection, which also carries longer focal lengths for narrow-field work such as inspection and barcode reading. Check live availability and the selected mechanical variant. M12 variants use an M12x0.5mm holder; M8 variants require an M8 holder or a suitable adapter.

도어벨 카메라 초소형 M8 어안 렌즈 D

195°@5.2mm 어안 렌즈

$29.00

.STP 파일 다운로드상품 보기
IMX415용 M8x0.35 렌즈

2.8mm 소형 렌즈

$29.00

.STP 파일 다운로드상품 보기
바슬러 Dart 카메라 IP67 M12 렌즈

Low Distortion 3.2mm M12 Lens

$39.00

.STP 파일 다운로드상품 보기
Blackfly S-마운트 카메라용 6mm M12 렌즈

고속 6mm M12 렌즈

$39.00

.STP 파일 다운로드상품 보기
IP67 12mm M12 렌즈

IP67 12mm M12 렌즈

$39.00

.STP 파일 다운로드상품 보기
IR 보정 16mm M12 렌즈

IR 보정 16mm M12 렌즈 8MP

$70.00

.STP 파일 다운로드상품 보기
75mm M12 렌즈

75mm M12 렌즈 (적외선 보정)

$129.00

.STP 파일 다운로드상품 보기
14mm M12 렌즈 CIL142

망원 14.2mm M12 렌즈

$59.00

.STP 파일 다운로드상품 보기

임베디드 비전 렌즈 둘러보기 | M12 렌즈, S-마운트 렌즈

선정 기준

여기에 소개된 모든 렌즈는 이미 보드 카메라 통합에 사용된 바 있는 M12 설계로, 범용 촬영용부터 특수한 초광각 용도까지 순서대로 나열되어 있습니다. 초점 거리와 F값을 기재한 이유는, 이 두 가지가 렌즈 선택 시 기준으로 삼는 고정된 사양이기 때문입니다. 주광선 각도(CRA)는 의도적으로 표의 항목에서 제외했습니다. CRA는 센서별 매칭 요건일 뿐, 렌즈의 주요 사양은 아니며, 최종 결정 전에 각 후보 렌즈를 사용자의 센서 마이크로렌즈 CRA 곡선과 대조하여 확인해야 합니다.

임베디드 카메라에는 어떤 렌즈 마운트가 가장 적합할까요?

M12(S-마운트)는 임베디드 비전 분야의 표준입니다. 3g-15g 규격으로 가장 작은 폼 팩터를 제공하며, 어댑터 플레이트 없이 PCB 장착형 홀더에 직접 나사로 고정할 수 있고, 산업용 C-마운트 제품보다 가격이 저렴합니다.

마운트 스레드 일반적인 무게 다음에 가장 적합합니다 컬렉션
M12 (S-마운트) M12×0.5mm 3g~15g 로봇공학, 드론, 엣지 AI, 보드 카메라 M12 렌즈
M8 M8x0.35 또는 M8x0.5 1g~5g 초소형 내시경용 마이크로 카메라 M8 렌즈
CS 마운트 1"-32 UN, 12.526mm 플랜지 50g~150g Compact industrial, Raspberry Pi High Quality Camera (C/CS version) CS 마운트 기초
C-마운트 1"-32 UN, 17.526mm 플랜지 50g~200g 완전한 산업용 고해상도 검사 C-마운트 렌즈

M8은 극한의 소형화를 위해 설계되었으며, 일반적으로 센서 커버리지가 최대 1/3인치이고 초점 거리 선택의 폭이 더 좁습니다. 더 넓은 센서 커버리지, 피사계 심도 조절을 위한 조절식 조리개 링, 또는 M12의 경직된 고정 조리개 바디로는 일반적으로 제공되지 않는 산업용 등급의 수차 보정이 필요할 때 CS 마운트와 C 마운트가 대안이 됩니다. M12, C 마운트, CS 마운트 비교 가이드를 자세히 확인해 보세요.

시스템의 구분

C-mount and M12 are different optical systems, not two sizes of the same thing. An adjustable C-mount lens focuses by rotating a ring, often paired with a separate iris ring; what that ring actually moves (the whole cell, a front group, or internal groups on a cam) is a design choice, so confirm it on the datasheet or with Commonlands engineering. The C-mount standard itself fixes the 1"-32 thread and the 17.526mm flange and nothing else, and C-mount lenses variously use unit focus, front-cell focus, or no focus adjustment at all.

M12 is a rigid optical assembly with no internal moving groups; focus is set by threading the entire lens in or out of the holder.

The same caution applies to "minimum object distance" (MOD). On a focus-ring C-mount lens the near limit arrives however that design fails: center focus unreachable at the ring's stop, field curvature pulling the edges away first, or the moving group running out of travel. An M12 lens has no focus ring, so its near limit comes from the particular design and the holder it sits in, usually some mix of thread length, barrel-to-holder clearance, and the field curvature and astigmatism that grow as the lens moves out.

Both limits are product-specific. Read them from the datasheet for the part you are specifying rather than from the mount name.

간단한 사양 비교

엔지니어들이 가장 많이 문의하는 임베디드 비전 렌즈의 사양 비교

렌즈 EFL F# 임베디드 분야에서 가장 적합한 용도
CIL078 7.8mm F/2.0 최대 1/1.7인치 크기의 8MP 센서를 활용한 범용 비전 (Jetson, Raspberry Pi)
CIL059 5.9mm F/1.7 고속 범용, 스테레오 및 검사용 카메라; IP67 등급 모델 제공
CIL326 2.9mm F/1.45 광각 저조도 감시, 실외용 카메라에 적합한 IP67 등급
CIL034 3.2mm F/2.3 저왜곡 SLAM 및 실외 로봇 공학; M12A 모델의 IP67 등급
CIL239 1.8mm F/2.0 1/4인치~1/3인치 센서를 이용한 적외선 보정 주야간 장애물 회피
CIL207 0.8mm F/1.9 220도 초광각 서라운드 뷰 및 장애물 감지

EFL and F-number values are as published on each linked product page. The CIL034 row shows its fastest variant; the same design also ships at F/2.7 and F/4.2 on its other sensor-resolution variants. Order reflects breadth of embedded use, not optical quality order. Use the field of view calculator to verify coverage for your specific sensor format.

임베디드 센서에 맞는 렌즈를 선택하는 방법

렌즈와 센서의 불일치는 비네팅, 색상 그라데이션, 또는 해상도 손실로 나타납니다. 다음 네 가지 매개변수가 서로 일치해야 합니다: 이미지 서클과 센서 대각선 길이, CRA와 센서 마이크로렌즈 설계, 렌즈 MTF와 센서 나이퀴스트 주파수, 그리고 후초점 거리와 센서 스택의 두께입니다.

이미지 서클은 센서의 대각선을 모두 덮어야 합니다.

The lens projects a circular image; your rectangular sensor sits inside that circle. An image circle smaller than the sensor diagonal produces vignetting at the corners. Moderate oversizing is usually acceptable for coverage; run the same CRA, clearance, stack, and MTF checks as any pairing. Undersizing vignettes the corners and fails whenever the image must fill the full frame. Circular-image fisheyes that place the whole image circle inside the frame are the deliberate exception.

센서 형식대각선
1/4인치4.5mm
1/3인치6.0mm
1/2.5인치7.2mm
1/2.3인치 (IMX477급)7.9mm
1/1.7인치9.5mm

1/2.5인치 센서용으로 지정된 렌즈는 해당 크기 이하의 모든 센서를 커버하지만, 1/1.7인치 센서에서는 비네팅 현상이 발생합니다. 데이터시트에는 이미지 서클이 밀리미터 단위나 센서 포맷 명칭으로 표기되는데, 두 값이 항상 동일한 정밀도로 공개되는 것은 아니므로, 제조사 간 포맷 명칭이 정확히 일치한다고 가정하기보다는 센서의 실제 대각선 길이를 기준으로 확인하시기 바랍니다. 전체 커버리지 계산에 대한 자세한 내용은 ‘센서 크기 및 렌즈 호환성’을 참조하십시오.

해상도: 렌즈의 MTF는 센서의 나이퀴스트 주파수를 충족해야 한다

A 12MP sensor with 1.55µm pixels has a monochrome Nyquist frequency near 322 lp/mm, and a Bayer sensor samples each color channel more coarsely than that. If the lens cannot resolve the frequency your task needs at your working aperture, the sensor's extra resolution goes to waste. Check the lens MTF chart at the aperture you intend to shoot.

Commonlands uses 20%-30% MTF at Nyquist as a starting point for embedded work, not a standard: what you actually need follows the contrast and SNR of the task, how much aliasing the pipeline tolerates, and which field positions carry the measurement. Validate it against your own images. The MTF curve guide explains how to read these charts.

초점 거리 계산을 직접 풀어보세요

EFL = (WD × sensor_width) / FOV_width A far-conjugate approximation, exact only in a pinhole ray model; finite-conjugate imaging uses Gaussian conjugates from the principal planes (Hecht, Optics, 5th ed., section 5.2). WD = working distance; FOV_width = horizontal scene width at that distance.

Run your sensor size, target field of view, and working distance through the field of view calculator or the EFL calculator to get the required focal length for your system, consistent with the same formula used above.

주광선의 각도가 내장 카메라의 화질에 미치는 영향

Chief ray angle (CRA) is the angle at which the lens delivers light to a given point on the sensor. Small-pixel sensors, common at 1.4µm-2.5µm in embedded cameras, use microlenses over each pixel tuned to a specific CRA curve. That curve runs from roughly 0 to 15 degrees at the edge on industrial and machine vision sensors, up to 25 to 35 degrees on mobile-class parts, so pull the curve for your sensor rather than assuming a typical value. When the lens CRA does not track the sensor's design CRA, you get color shading (red, green, and blue channels fall off differently toward the edges) and reduced corner brightness that software cannot fully correct, because the mismatch is wavelength- and angle-dependent at the pixel level rather than a uniform gain error.

This matters most on the small-pixel sensors that dominate embedded and board-camera designs. Sensor datasheets specify a CRA curve; lens datasheets specify a matching CRA spec or curve. When selecting a lens for a sensor with sub-2µm pixels, check that the two curves track across the field, not just at the center. Curve overlap is a screen, not an acceptance test: the tolerable difference depends on the full ray cone at each field point, so on working F-number, plus the wavelength band, the pixel and filter stack, and the corner shading and MTF loss your pipeline accepts. Settle it with flat-field and corner MTF measurements. The full mismatch mechanics and matching procedure are in the chief ray angle and mismatch guide.

이것이 임베디드 설계에 어떤 영향을 미치는가

CRA 불일치는 초기 구동 단계에서는 중앙 영역의 화질이 양호해 보이기 때문에 간과하기 쉽습니다. 이 문제는 모서리나 가장자리에서 나타나며, 대개 특정 조명 조건에서만 발생하거나 센서 개량으로 인해 마이크로렌즈 설계가 변경된 후에야 드러납니다. 새로운 카메라 모듈용 렌즈를 확정하기 전에 CRA 호환성을 반드시 확인해야 하며, 현장에서 색상 편차가 나타난 후에 확인해서는 안 됩니다.

Jetson 및 Raspberry Pi 카메라 모듈의 보드 수준 통합

CMOS 센서, M12 홀더 및 M12 렌즈의 분해도
보드 레벨 카메라는 렌즈, 홀더, 센서를 하나의 모듈로 통합합니다.

MIPI CSI-2 is an electrical interface between the sensor and the host processor, not a lens mount, and no compute platform defines one. Mount style belongs to the camera board. Plenty of Jetson and Raspberry Pi camera boards do carry an M12 holder soldered or clipped to the PCB, which is why M12 dominates this space, but Raspberry Pi's own line covers three cases: fixed integrated optics on Camera Module 2 and Camera Module 3, and the High Quality Camera, sold both in a C/CS-mount version that ships with a C-mount adapter and in a native M12-mount version.

Common sensors on these boards are the IMX477 (High Quality Camera), IMX219 (Camera Module 2), and IMX708 (Camera Module 3). Read the mechanical drawing for the board you are building on before ordering a lens. Because M12 has no standardized flange distance, focus is set entirely by how far the lens threads into the holder, and back focal length (BFL) varies by lens design.

That variability helps at the board level. When the same lens design moves onto a module whose cover glass and IR filter stack is a different thickness, a holder of the correct height brings the sensor back to the lens's focus position, which is cheaper than requalifying a lens. Confirm holder height against the lens's specified back focal length and your full sensor stack (bare sensor, cover glass, IR filter, any spacer) before finalizing the PCB footprint. The M12 lens holder selection guide covers holder height selection and thread engagement in detail.

Holder height only buys back focus. A thicker or thinner plane-parallel stack sitting in a converging beam adds its own spherical aberration and axial color, and any wedge in that stack tilts the image plane. Moving the lens along the axis corrects none of that.

A different filter also moves the passband, shifting where an IR-corrected design lands in focus, and an interference cut filter shifts its cut-off with ray angle, so the corner response moves differently from the center. Measure corner MTF and color shading on the new module rather than assuming the refocus closed the gap.

Multi-camera Jetson and Raspberry Pi designs raise the integration bar further. A stereo pair should be closely matched in focal length and distortion profile, because those set the disparity-to-range scale and the rectification accuracy, and the rig needs synchronized exposure plus extrinsics that hold their calibration. Back focal length is the one difference that does not need matching: each module is focused individually, which absorbs it.

Bulk-buying from a single production lot reduces optical unit-to-unit spread but does not eliminate it, so verify focus at the corners of the field on each unit during bring-up, not only at the center.

성능, 크기, 비용의 삼각관계

임베디드 렌즈 선정은 광학 성능, 물리적 설치 공간, 단가라는 세 가지 요소 간의 절충 관계이며, 전력 소비는 설치 공간과 연계된 부차적인 요소로 작용합니다. 고정형 산업용 검사 스테이션과 달리, 임베디드 시스템은 대개 이 삼각형의 한쪽 요소를 우선시할 경우 다른 두 요소에서 타협을 피할 수 없습니다.

M12 lenses sit at the small-footprint, low-cost corner. A 3g-15g lens with a fixed aperture draws no power itself and costs a fraction of an industrial optic, but gives up the adjustable iris and ring-driven focus that C-mount designs such as Commonlands' provide. C-mount and CS-mount sit at the opposite corner: an iris ring lets you trade depth of field for light throughput on demand and a focus ring refocuses without re-threading the lens, but the lens weighs 3x-10x more and costs more per unit. For a drone or handheld device on battery power, that weight difference is a meaningful chunk of flight time or user fatigue, not just a spec sheet number.

조리개 제어 역시 덜 눈에 띄는 방식으로 광량과 상호작용합니다. C-마운트의 가변 조리개는 머신 비전 분야에서만 실용적입니다. 이는 일반적으로 조명이 프로그래밍 방식으로 제어되기 때문인데(구조화 조명, LED 링 라이트, 백라이트 어레이 등), 이를 통해 시스템은 센서에 빛이 부족해지지 않도록 하면서도 피사계 심도를 확보하기 위해 조리개를 조일 수 있습니다. 반면, 주변광이나 제어되지 않은 조명에 의존하는 임베디드 시스템은 항상 이러한 절충을 할 수 없기 때문에, 대신 빠른 F-값을 가진 고정 조리개 M12 렌즈를 선택하는 쪽으로 결정이 기울게 됩니다.

실용적인 기본값

대부분의 임베디드 설계는 고정 조리개를 갖춘 M12를 기본으로 채택하며, 조리개 제어 기능의 상실을 감수합니다. 반면 C-마운트는 고해상도 검사 모듈이나 특정 내구성 강화 SKU가 필요한 실외용 인클로저와 같이, 추가적인 크기와 비용을 감수하더라도 해당 애플리케이션에 실제로 필요한 기능을 확보할 수 있는 일부 임베디드 애플리케이션에만 한정적으로 사용됩니다. 내구성 강화 자체는 C-마운트 형식 전체의 특성이라기보다는 선택적이며 SKU별로 상이한 기능입니다.

구매 결정을 내리기 전에 확인해야 할 주요 사양

초점 거리

초점 거리가 짧을수록 동일한 센서에서 더 넓은 시야를 확보할 수 있습니다. 2mm~4mm는 장애물 회피를 위한 초광각 시야를 제공합니다. 4mm~8mm는 범용 비전 용도로 사용됩니다. 8mm~16mm는 검사 및 바코드 판독에 적합한 좁은 시야를 제공합니다. EFL 계산기를 사용하여 대상 촬영 영역과 작동 거리를 바탕으로 초점 거리를 구해 보세요. 전체적인 방법에 따른 초점 거리 선택 방법은 관련 문서를 참조하십시오.

F값 (조리개)

F값이 낮을수록 더 많은 빛을 받아들입니다. F/1.4 렌즈는 F/2.8 렌즈보다 대략 4배 더 많은 빛을 통과시킵니다. 그 대가로 피사계 심도가 얕아집니다. 저조도 임베디드 비전 환경에서는 F/1.4~F/1.8을 우선적으로 고려해야 하며, 빛의 수집량보다 피사계 심도가 더 중요한 경우에는 F/2.0~F/2.8을 선택하는 것이 합리적입니다. 피사계 심도 계산기를 통해 수치를 확인해 보고, 머신 비전 분야의 F값 항목을 참고하여 두 요소 간의 기본 관계를 파악해 보십시오.

왜곡

Barrel distortion bends straight lines into curves. No fixed percentage is required by an application: what a measurement pipeline tolerates depends on the camera model it calibrates to, how well features localize at the field positions being measured, the accuracy the task needs, and whether the compute budget covers an undistort pass. Distortion the calibrated model captures gets corrected; distortion the model does not fit becomes residual error. Standard wide-angle M12 lenses commonly run 10%-20% distortion, and Commonlands low-distortion models bring that under 1%, which keeps an uncalibrated pinhole model usable. See the low-distortion lens guide.

열적 안정성

Thermal range is wider outside a climate-controlled factory. An embedded camera in a vehicle or an outdoor enclosure can see -30 degrees C to +70 degrees C across a day, and a drone camera can move from sun-heated ground to cold altitude in minutes. Thermal expansion and the temperature dependence of refractive index shift the focal plane as the assembly heats and cools, and at fast apertures on small-pixel sensors the depth of focus is tight enough that a poorly athermalized lens can drift out of focus with no mechanical fault involved. Construction is one screening input, not a thermal spec: suitability is settled by a focus or MTF measurement across your operating temperature range on the assembled lens, holder, and sensor, and Commonlands can run that test on request.

무게

이는 드론, 휴대용 기기, 로봇 팔과 같은 장비에서 특히 중요한데, 이러한 장비의 경우 추가되는 질량이 비행 시간, 사용자의 피로도 또는 서보 부하에 영향을 미치기 때문입니다. M12 렌즈의 무게는 일반적으로 3g~15g이며, C-마운트 렌즈는 일반적으로 50g~200g입니다. 광학 사양을 충족하면서도 가장 가벼운 렌즈를 선택하십시오.

IP 등급

IP67, defined in IEC 60529, means dust-tight plus 30 minutes under a meter of water. That is an immersion test, not a rain or spray test. IP6K9K (industry shorthand IP69K) comes from ISO 20653, a road-vehicle standard with its own high-pressure, high-temperature jet procedure. They are separate standards run as separate tests, so cite them separately rather than as one washdown rating.

Ratings apply to the tested lens variant in its mounted configuration under the standard's water and dust exposures; they do not cover steam, detergents, repeated sanitation cycles, or the rest of the camera. Where the lens sits behind a sealed window in a rated housing, the housing carries the requirement and the lens may need no individual code. Match the test to the exposure the camera actually sees.

See the IP rating guide for test methods, and note that ruggedization is a selective feature on specific SKUs, not a property of all C-mount or M12 lenses; see the ruggedized lens guide.

개별 렌즈 대 번들 모듈 광학 시스템

Arducam이나 e-con Systems와 같은 카메라 모듈 공급업체들은 센서와 광학 부품이 이미 결합된 보드를 공급하는데, 이는 단일한 고정 자재 명세서를 원할 때 편리합니다. 주광선 각도를 특정 센서에 맞추거나, IR 차단 필터나 대역통과 필터를 추가·교체해야 하거나, 양산 과정에서 왜곡 및 이미지 서클 사양을 일관되게 유지해야 할 경우에는, 사양이 엄격히 제어된 개별 M12 렌즈를 사용하는 것이 엔지니어링 측면에서 더 나은 선택입니다. 초점 거리를 확정하기 전에 시야각 계산기나 EFL 계산기를 통해 센서, 목표 시야각, 작동 거리를 확인해 보십시오.

어떤 렌즈를 골라야 할지 모르시겠나요?

사용 중인 센서 모델과 목표 시야각을 알려주세요. 설계에 착수하기 전에 이미지 서클 커버리지와 CRA 호환성을 확인해 드리겠습니다.

엔지니어링 부서에 문의하기

자주 묻는 질문

보드 레벨 카메라용 광학 부품을 선정할 때 엔지니어들이 가장 자주 묻는 질문

임베디드 비전 시스템용 렌즈는 어떻게 선택해야 할까요?

센서 형식, 마운트 유형, 시야각, 작동 환경이라는 네 가지 제약 조건부터 시작하십시오. 센서 형식은 최소 이미지 서클을 결정합니다. 대부분의 임베디드 카메라는 소형화를 위해 M12를 사용합니다. 작동 거리와 필요한 시야각을 바탕으로 초점 거리를 계산한 다음, IP 등급, IR 보정 기능, 그리고 센서의 마이크로렌즈 설계와 CRA 호환성을 기준으로 필터링하십시오.

임베디드 카메라에는 어떤 렌즈 마운트가 가장 적합할까요?

M12 (S-mount) is standard for embedded vision: 3g-15g, threads directly into a PCB-mounted holder, and covers sensors up to 1/1.8 inch typically, with select designs to 2/3 inch. That range takes in the IMX477, IMX219, and IMX708. Choose M8 for ultra-compact designs. Choose C-mount or CS-mount when you need a larger sensor, an adjustable iris, or a level of aberration correction the chosen M12 design does not reach.

M12 렌즈는 NVIDIA Jetson 카메라와 호환되나요?

Yes. Many Jetson-compatible camera boards use M12x0.5mm lens holders, including the native M12-mount version of the Raspberry Pi High Quality Camera and a range of Arducam modules. MIPI CSI-2 is an electrical interface and does not set the mount, so confirm it on the board. M12 has no fixed flange distance, so threading the lens in or out sets focus across modules with different sensor stack thicknesses. Focus is all it sets: a stack of different thickness still changes the aberration correction reaching the sensor.

임베디드 비전에는 어떤 초점 거리가 필요할까요?

Focal length sets field of view for a given sensor and working distance. At 0.5m-2m, 4mm-8mm covers general-purpose vision. 2mm-4mm suits obstacle avoidance and surround view. 8mm-16mm suits inspection and barcode reading. Use EFL = (WD x sensor_width) / FOV_width, or the Commonlands EFL calculator, to solve for the required focal length.

CRA는 내장 카메라의 화질에 어떤 영향을 미치나요?

Chief ray angle (CRA) is the angle at which the lens delivers light to each point on the sensor. Sensor microlenses are tuned to a CRA curve, from roughly 0 to 15 degrees at the edge on machine vision sensors up to 25 to 35 degrees on mobile-class parts, so pull the curve for your sensor rather than assuming one value. A lens CRA that does not track the sensor's design CRA produces color shading and corner brightness falloff that software cannot fully correct, because the mismatch is wavelength- and angle-dependent at the pixel level.

임베디드 시스템용으로 볼 때, 전면이 유리로 된 M12 렌즈가 플라스틱 렌즈보다 더 나은가요?

Construction is a first-pass filter, not a verdict. Glass surfaces resist UV exposure and scratching better than exposed plastic, which is why all-glass, all-metal builds are the common shortlist for industrial, robotics, and outdoor use. Thermal suitability is a different question: it comes from measured focus or MTF over temperature for the full lens-holder-sensor assembly, a test Commonlands can run on request. Plastic elements remain a reasonable choice for cost-sensitive, climate-controlled consumer devices.

센서 스택에 맞는 M12 렌즈 홀더의 크기를 어떻게 결정하나요?

홀더 높이는 렌즈의 후면 초점 거리와 전체 센서 스택(베어 센서, 커버 글라스, IR 필터 및 모든 스페이서)에 맞춰야 합니다. M12에는 표준 플랜지 거리가 없기 때문에, 동일한 렌즈라도 카메라 모듈에 따라 필요한 홀더 높이가 달라질 수 있습니다. PCB 풋프린트를 최종 확정하기 전에 렌즈 데이터시트를 참조하여 홀더 높이를 확인하십시오. M12 렌즈 홀더 선정 가이드를 참조하십시오.

하나의 M12 렌즈를 여러 대의 Jetson 또는 Raspberry Pi 카메라 모듈에 모두 사용할 수 있나요?

Often yes, within limits. Because M12 focus is set by threading depth rather than a fixed flange, the same lens design can pair with different MIPI-CSI2 modules as long as holder height accommodates each module's sensor stack and the lens image circle covers the sensor. Threading restores focus, not correction: a stack of different thickness changes spherical aberration and axial color, and wedge in the stack tilts the field. Check corner MTF per module rather than assuming it.

임베디드 렌즈 선정 시 출력, 크기, 비용 간의 상충 관계는 무엇인가요?

Smaller lenses with fixed apertures cost less and draw no power, but give up the adjustable iris and ring-driven focus that C-mount designs provide. A C-mount lens adds those controls at 3x-10x the weight and higher unit cost; how a given design implements focus, and how it behaves near its close limit, differ between products, so verify both on the datasheet. Battery- and drone-powered embedded systems typically default to M12 and accept the fixed-aperture tradeoff unless the application specifically needs iris control.

임베디드 카메라 이미지에서 색상 불균일 현상이 발생하는 원인은 무엇이며, 이를 어떻게 해결할 수 있나요?

이미지 가장자리 쪽으로 나타나는 색상 그라데이션은 대개 렌즈와 센서의 마이크로렌즈 설계 간 주광선 각도(CRA) 불일치에서 기인하는 것이지, 소프트웨어 화이트 밸런스 문제 때문은 아닙니다. 이러한 불일치는 각도와 파장에 따라 달라지기 때문에 소프트웨어 보정만으로는 부분적으로만 보완할 수 있습니다. 이를 해결하려면, 렌즈의 CRA 곡선이 화각 전반에 걸쳐 센서 설계의 CRA 곡선을 따르는 렌즈를 선택해야 하며, 통합 전에 양쪽 데이터시트를 대조하여 이를 확인해야 합니다.

임베디드 카메라에 적합한 렌즈를 선택하는 데 도움이 필요하신가요?

사용하시는 센서 모델, 목표 시야각 및 작동 환경을 저희에게 알려주십시오. 당사의 광학 엔지니어들이 초점 거리, 조리개 및 필터 구성을 제안해 드리고, 귀하께서 설계를 확정하기 전에 CRA 호환성을 확인해 드립니다.